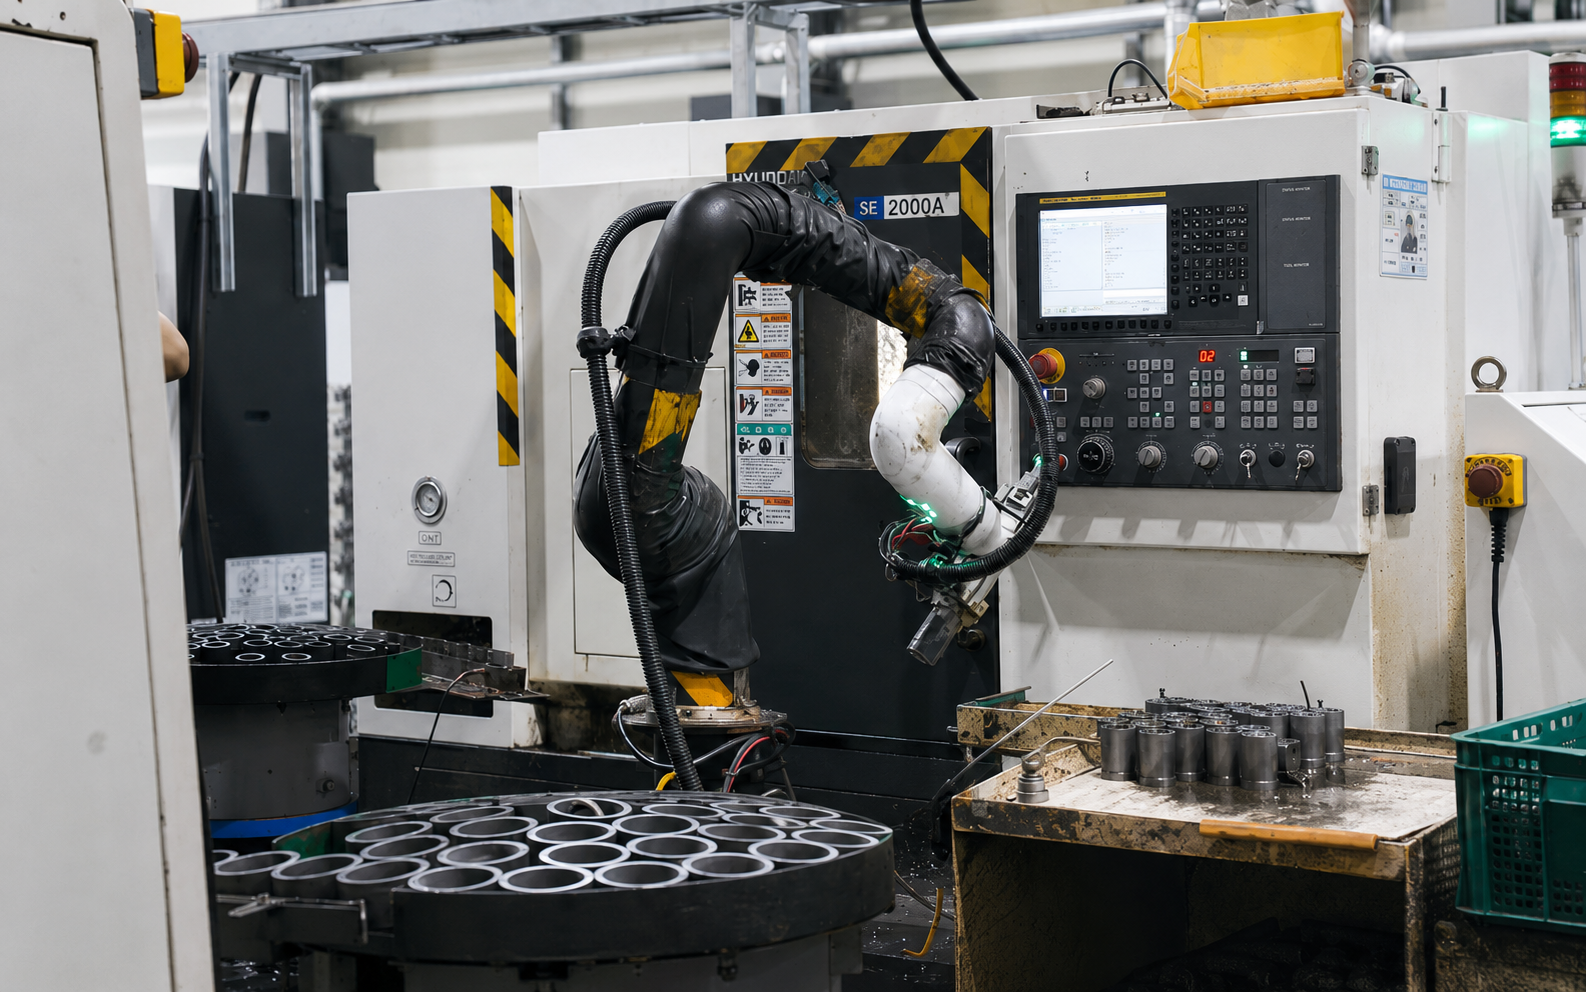
Machine Tending Automation

Automate repetitive machine tending.

Neuromeka collaborative robots automate repetitive tasks from loading raw parts to unloading finished components, helping manufacturers increase machine utilization and reduce manual labor. Our systems can be configured around your parts, fixtures, cycle time, and floor space.

How It Works

01

Load Raw Parts

An operator loads raw workpieces into a tray, pallet, rack, or other infeed system.

02

Identify and Prepare the Part

The system can use fixed part locations, sensors, barcodes, vision, or measurement systems to identify the workpiece and confirm the correct process.

03

Load the Machine

The robot picks the workpiece and places it into the machine or process fixture.

04

Start the Machine Cycle

The robot coordinates with the machine to begin the process.

05

Unload the Finished Part

When the cycle is complete, the robot removes the processed part and transfers it to the designated outfeed location.

06

Continue Production

The system repeats the cycle automatically for the next workpiece.

Depending on the application, the system can also incorporate part identification, orientation, inspection, air blowing, measurement, and pallet or tray handling.

Built Around Your Application

A standard robot cell can be configured around your existing equipment and production process.

Machine Compatibility

The system can be integrated with:

  • CNC lathes
  • Vertical and horizontal machining centers
  • Injection molding machines
  • Presses and forming equipment
  • Washing and cleaning systems
  • Inspection and testing equipment
  • Packaging and processing equipment
  • Custom or legacy equipment

Integration requirements are evaluated based on the machine's available I/O and communication capabilities.
Part Handling

End-of-arm tooling is selected based on part and process requirements, including:

  • Electric grippers
  • Pneumatic grippers
  • Dual grippers for raw and finished parts
  • Vacuum grippers
  • Custom fingers
  • Quick-change tooling

The system can be designed to handle variations in part size, shape, weight, and surface finish.

Part Infeed and Outfeed

Choose the material presentation method that fits your application:

  • Trays
  • Pallets
  • Totes
  • Racks
  • Conveyors
  • Custom fixtures

For higher-mix applications, vision or flexible part presentation can also be incorporated.

Optional Features

  • Part orientation
  • Barcode or QR code identification
  • Probe or dimensional inspection
  • Air-blow cleaning
  • Chip removal
  • Part measurement
  • Pass/fail sorting
  • Finished-part stacking
  • Machine door control
  • Multi-machine tending

What's Included

A typical Neuromeka machine tending solution may include:

Collaborative Robot icon

Collaborative Robot

Neuromeka cobot selected based on the required payload, reach, and workspace.

Robot Controller icon

Robot Controller

Neuromeka controller and robot control software for operation and coordination.

End-of-Arm Tooling icon

End-of-Arm Tooling

Application-specific gripper or tooling designed to securely handle the workpiece.

Machine Integration icon

Machine Integration

I/O or other communication required to coordinate the robot and machine.

Part Presentation icon

Part Presentation

A tray, pallet, rack, conveyor, or custom fixture for organizing incoming and finished parts.

Software and Programming icon

Software and Programming

Robot programming and process sequencing for the automated workflow.

Key Features

Flexible Around Your Existing Equipment

Our systems can be designed to work with new or existing machines and equipment. The application is evaluated around your machine interface, available space, workholding, and production workflow.

Easy Part Changeover

Depending on the application, part changes can be supported through interchangeable gripper fingers, adjustable fixtures, or software-based program selection.

Compact Automation

Collaborative robots can be integrated into compact workspaces where traditional industrial automation may require a larger footprint.

Expandable System Design

Start with a single machine and expand the automation system as production requirements grow.

Simple Operation

Operators can focus on loading material, managing production, and higher-value tasks while the robot handles repetitive machine tending.

Application Examples

CNC Turning

A robot loads raw material into a CNC lathe, unloads the finished part, and transfers it to the next process.

Machining Centers

A robot loads and unloads workpieces from a vise or fixture while supporting additional operations such as air blowing or inspection.

Injection Molding

A robot removes molded parts from the machine and places them onto a conveyor, tray, or downstream process.

Press Tending

A robot loads material into a press and removes the processed part after the cycle is complete.

Washing & Cleaning

A robot loads parts into an industrial washing or cleaning system and transfers them after processing.

Inspection-Integrated Tending

The robot loads a part into a machine or inspection station, removes it after processing, and separates acceptable and rejected parts.

Multi-Machine Tending

One robot services multiple machines, coordinating its sequence based on each machine's status.

Machine-to-Machine Transfer

A robot transfers parts between machines as part of a multi-step production process.

Ready to automate your machine tending?

Discuss your application with one of our experts who will help you build a solution around your process.

Book a Meeting